Advanced Metal Research on GitHub.
Open-source, AI-native industrial robots.
Advanced Metal Research makes open-source, AI-native industrial robots, machined and assembled in the USA. Every function unlocked, programmable from the pendant, in code or with any AI, with skills on top, starting with welding.
This page lists our public repositories and the write-ups we publish from GitHub. It rebuilds itself every day.
- Public repositories
- 3
- Stars
- 24
- Languages
- 2
- Write-ups
- 2
JavaScript, Python
Public repositories.
Every public repository in the organization, most recently updated first. Descriptions come from each repository; where one is missing, the opening of its README is shown instead.
-
01Python
rosie-sim-kits
Rosie robot URDF, MuJoCo, STEP, GLB and robot.json (mirror of advancedmetalresearch.com)
- gltf
- industrial-robot
- mujoco
- robot-simulation
- robotics
- step
- urdf
- Stars
- 1 star
- Updated
-
02PythonMIT
GradientOS
From the README GradientOS is a robot control and offline programming stack for Gradient Robotics arms. It combines a realtime controller, an HTTP/SSE API, and a web operator interface for trajectory and weld workflows.
- Stars
- 23 stars
- Updated
-
03JavaScriptThis page
advanced-metal-research.github.io
Advanced Metal Research on GitHub
- Stars
- 0 stars
- Updated
Write-ups.
Public pages we host on GitHub Pages: replications of robot-learning papers, run in simulation on our Rosie robots. Titles and summaries are read from each page when this site is built.
-
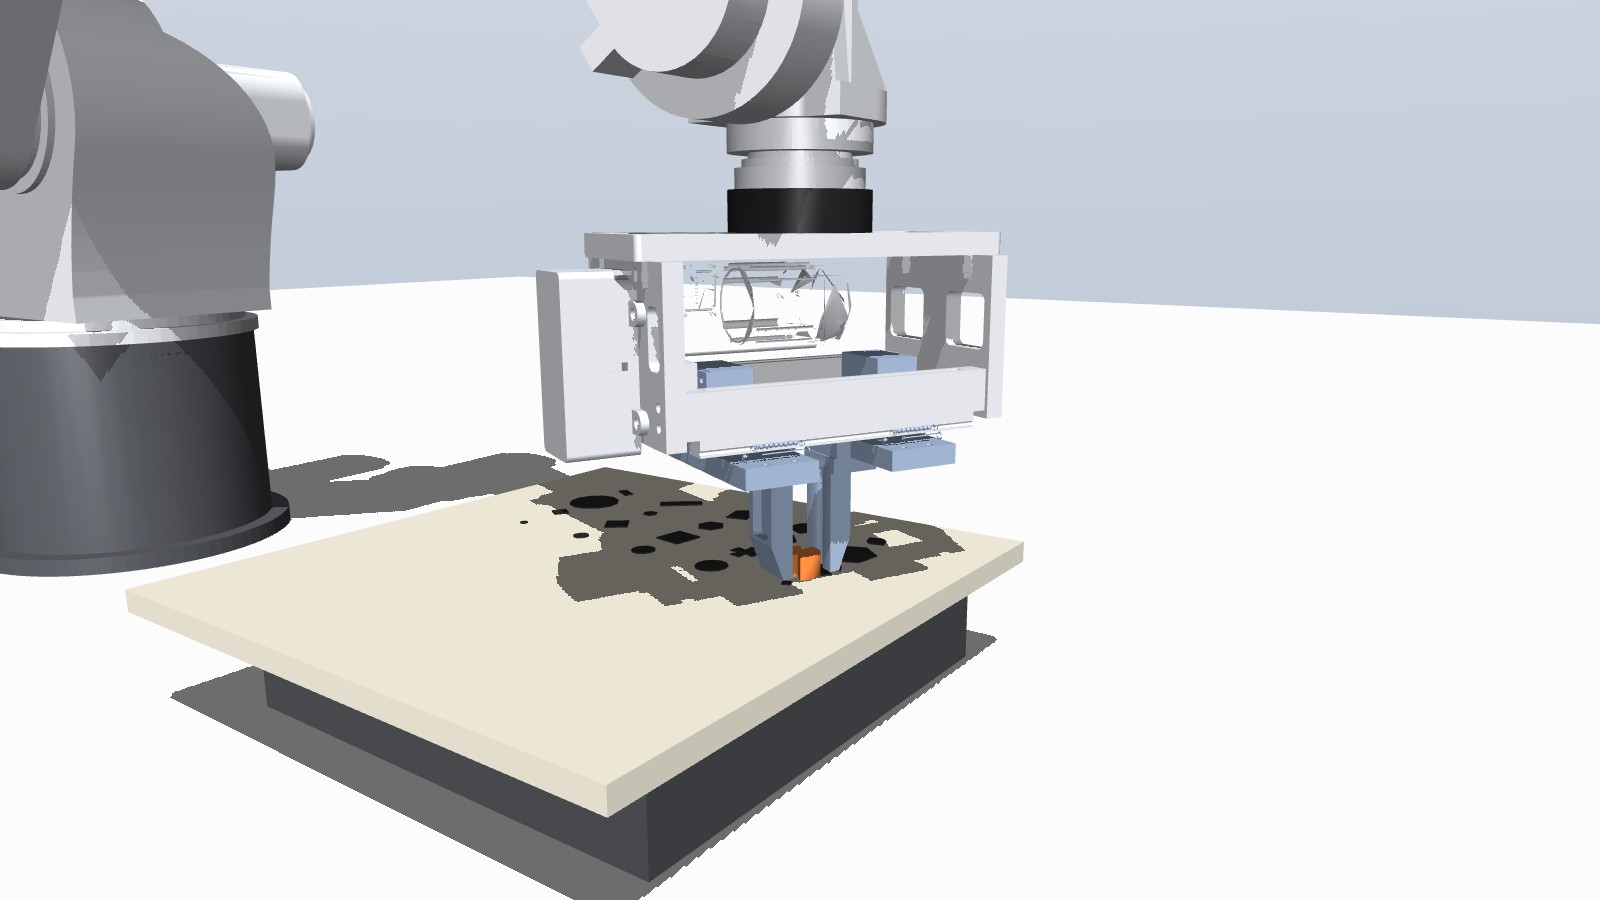
Replicating AlphaNIST, then moving it onto our Rosie arms
A lab note on re-implementing AlphaNIST (one RL policy, binary task reward, reset bank, beta sampling) on a CPU-sized NIST board, then on Rosie 600/1000/1400 arms with the SendCutSend compact gripper.
-
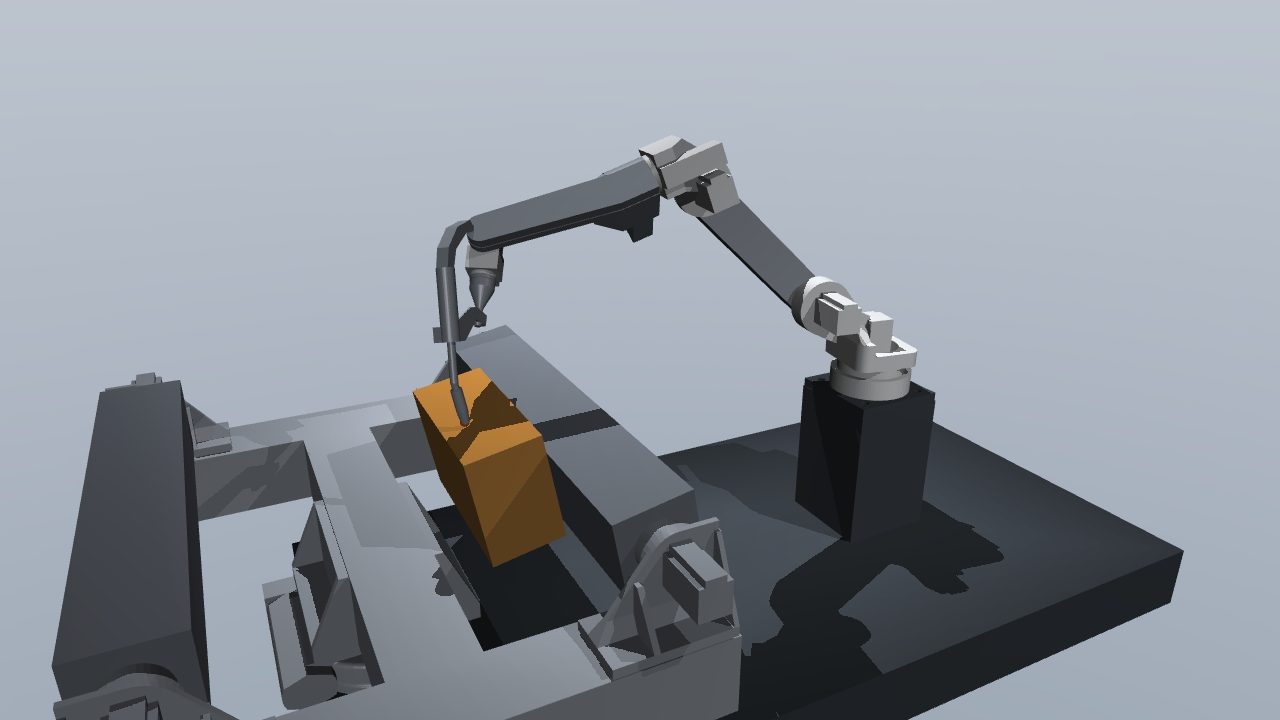
Feeding the frontier: replicating Success Guided Sampling on a welding robot
We reimplemented Success Guided Sampling (CoRL 2026) from scratch and tested it on two AMR Rosie welding cells, from a laptop CPU to 262,144 parallel environments on cloud GPUs.